
From orbit
to ocean floor.
One platform for the whole water column — satellite bathymetry, explainable multibeam to S-44, topography and forecasting.
Coast to full depth,
in one place.
SDB owns the shallows, multibeam owns the vessel-reachable deep, and both emit the same S-44 surface. No stitching between desktop tools.
Bathymetry
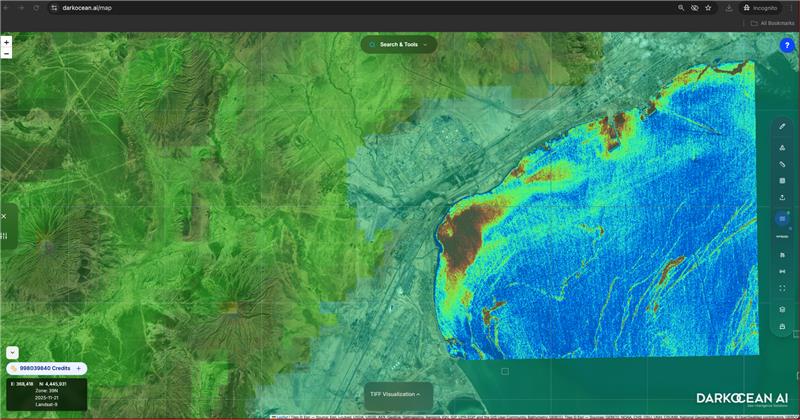
Turn a year of free Sentinel-2 and Landsat imagery into depth below chart datum (LAT), no vessel required. Powered by the Fusion model, checked against NASA ICESat-2 LiDAR, delivered as a Cloud-Optimized GeoTIFF.
NAVTopo
The on-land counterpart — free Copernicus GLO-30 into shaded relief, hypsometric tint and adaptive contour lines, from a 1 m floor to 50 m in high relief.
Multibeam · S-44
Ingest .kmall / .s7k / GSF, clean with explainable AI, grid with CUBE, and produce an IHO S-44 compliance certificate — web-native and collaborative.
Forecast
Copernicus Marine wave, current and wind with GO / NO-GO operability windows for personnel transfer, marine survey, heavy lift and diving / ROV.
Every colour
is a fixed depth.
One absolute depth-to-colour scale means a hue always means the same depth — comparable across every scene, every survey, every year. Land is masked, failed scenes raise a real error, and nothing is faked.
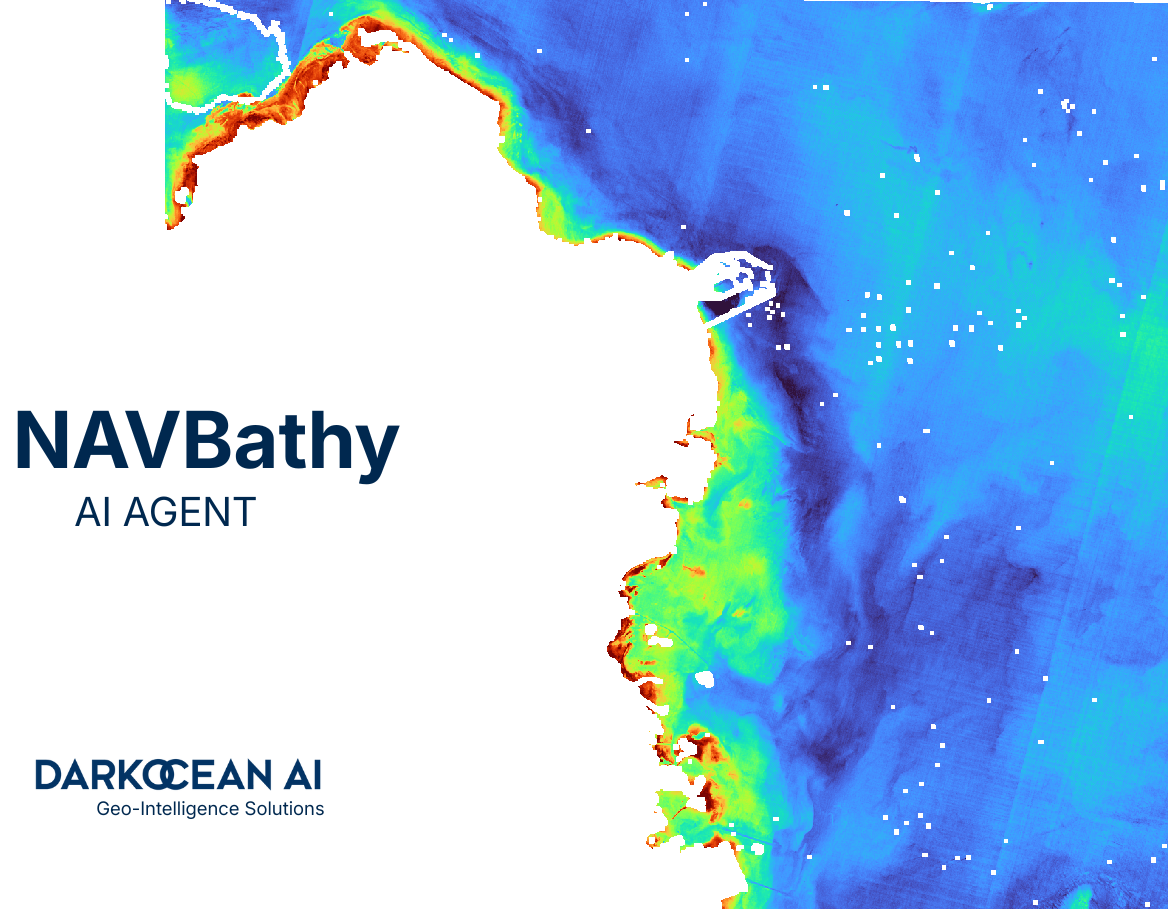
Scout. Process. Deliver.
Scout
Draw an area of interest. NAVBathy gathers a year of Sentinel-2 and Landsat 8/9 imagery via STAC and builds a 12-month multi-scene composite, not a single snapshot.
Process
The Fusion model combines the composite with water-optics features and EOT20 tides, then applies a local correction from the area's own NASA ICESat-2 tracks when available. If fusion can't run, standard SDB takes over automatically.
Deliver
Depth in metres below LAT. Download a Cloud-Optimized GeoTIFF, XYZ points, isobath contours or a 3D mesh, or push straight to a project. Water deeper than ICESat-2 can confirm is marked “not measured”.
Satellite bathymetry that knows the tide, the water and its own limits.
Bathymetry now runs on the Fusion model: one machine-learning depth model that fuses a year of satellite imagery, water optics and tides, checked against NASA ICESat-2 LiDAR. Built for reconnaissance and planning your survey.
A year, not a snapshot
12-month Sentinel-2 and Landsat 8/9 composites, plus water-optics features (Kd490 light attenuation, optical depth limit) and EOT20 tides.
Global model
Trained on 23 sites worldwide against about 72,000 NASA ICESat-2 seabed depths, across clear, moderate and turbid water.
Local correction
Tuned to each area's own ICESat-2 LiDAR tracks when they are available.
Depth below LAT
Metres below chart datum, positive down, with datum, units and sign embedded in the GeoTIFF. 10 m native resolution.
It shows where it can't see.
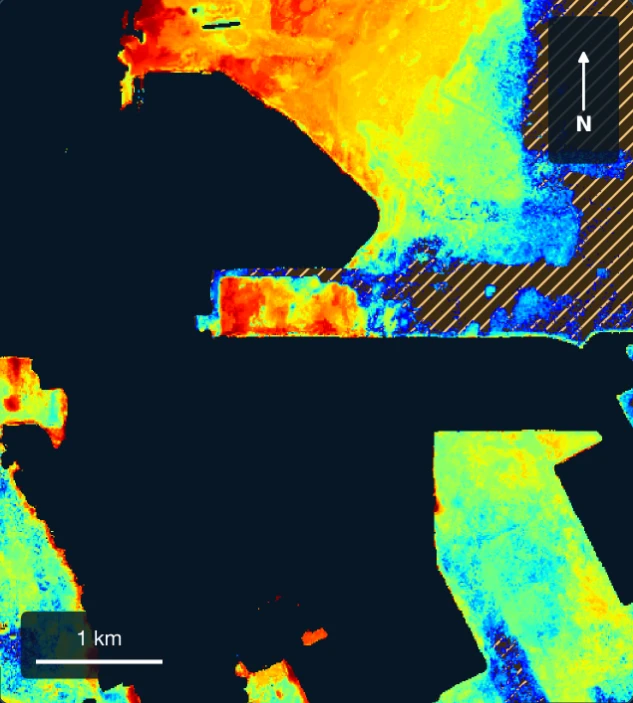
Where water is deeper than local ICESat-2 can confirm, the map is hatched “Beyond optical depth limit — not measured” instead of showing a guess.
| Water | Up to 15 m | All depths |
|---|---|---|
| Clear | 0.45 m | 1.46 m |
| Moderate | 0.66 m | 0.72 m |
| Turbid | 0.63 m | 0.65 m |
| Overall | 0.63 m | 0.80 m |
Typical depth error (MAE) against 70,169 NASA ICESat-2 points across 23 sites. Each site was scored by a model trained only on the other 22.
Cleaning you
can explain.
An XGBoost classifier scores every sounding; SHAP gives a signed reason for each decision. Confident points auto-resolve — the uncertain middle becomes review cases. Possible seabed features are never auto-rejected.
P(noise) < 0.20 — clean seabed, resolved automatically.
Possible real feature — flagged and retained. Safety of navigation.
P(noise) > 0.80 — logged, with SHAP rationale.
| Order | 1a | a = 0.50 · b = 0.013 |
| TVU @ 95% | √(a² + (b·d)²) | within limit |
| Nodes passing | 98.7% | coverage 100% |
| Surface | CUBE | BAG 1.6.2 |
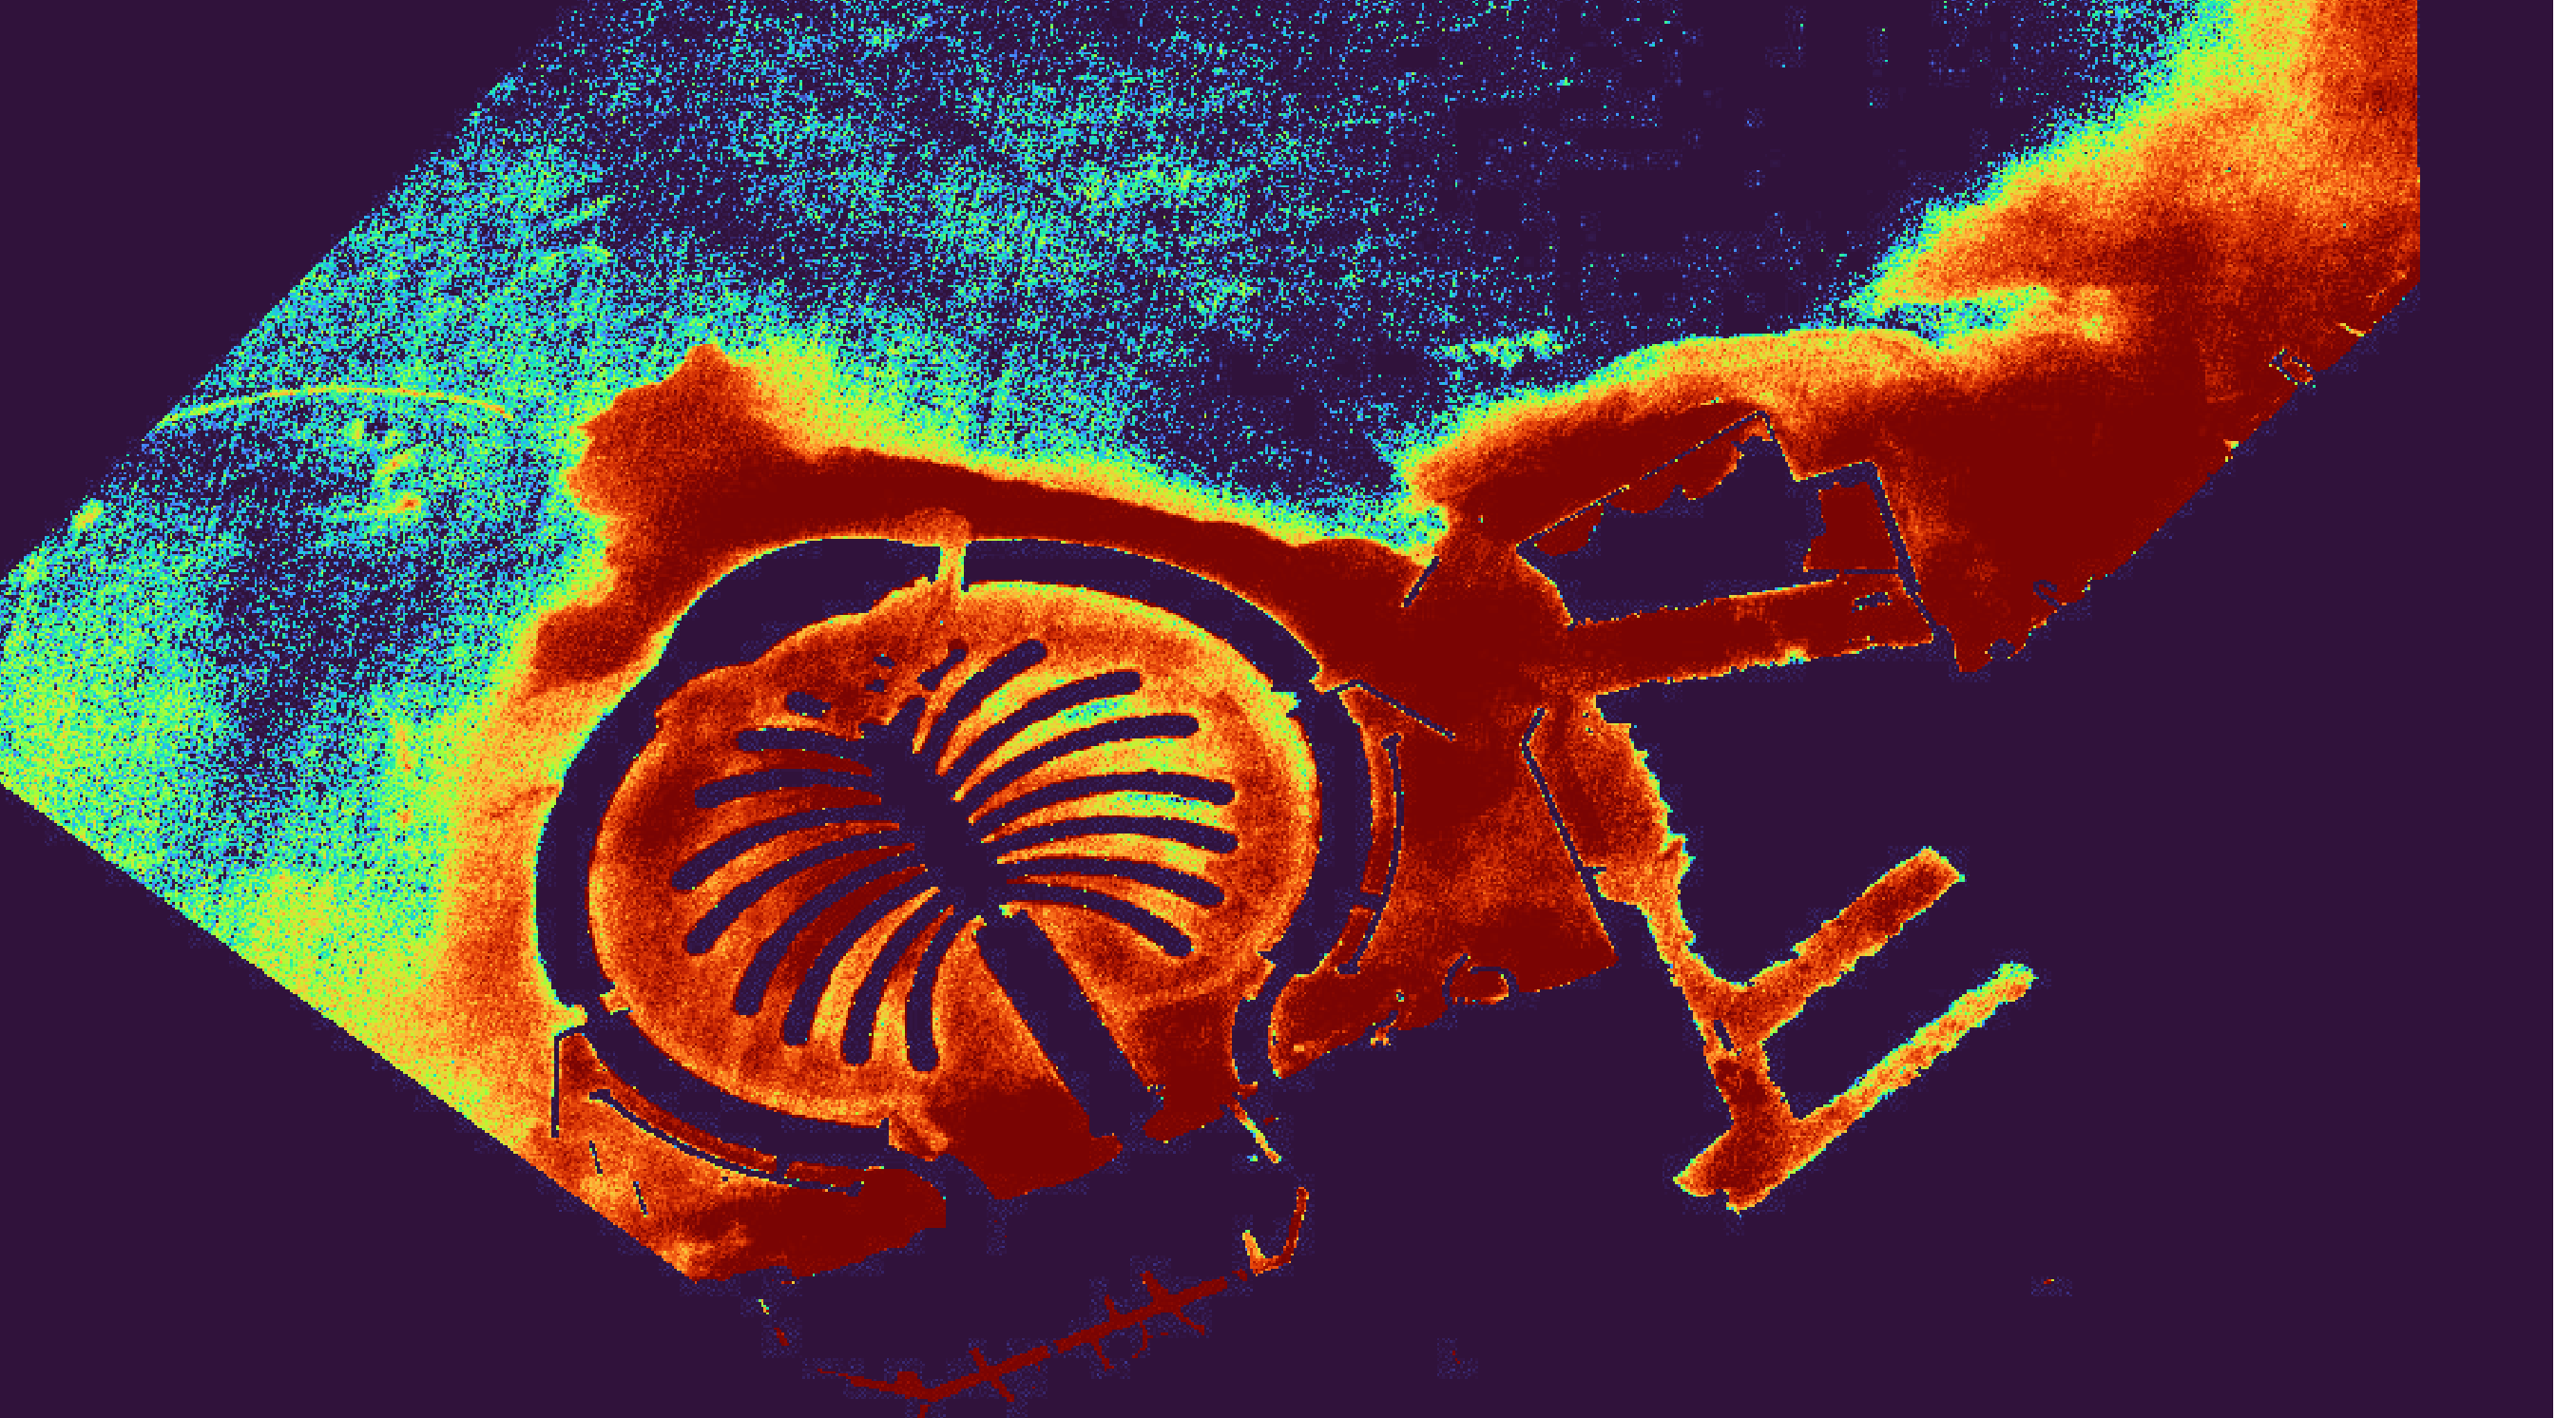
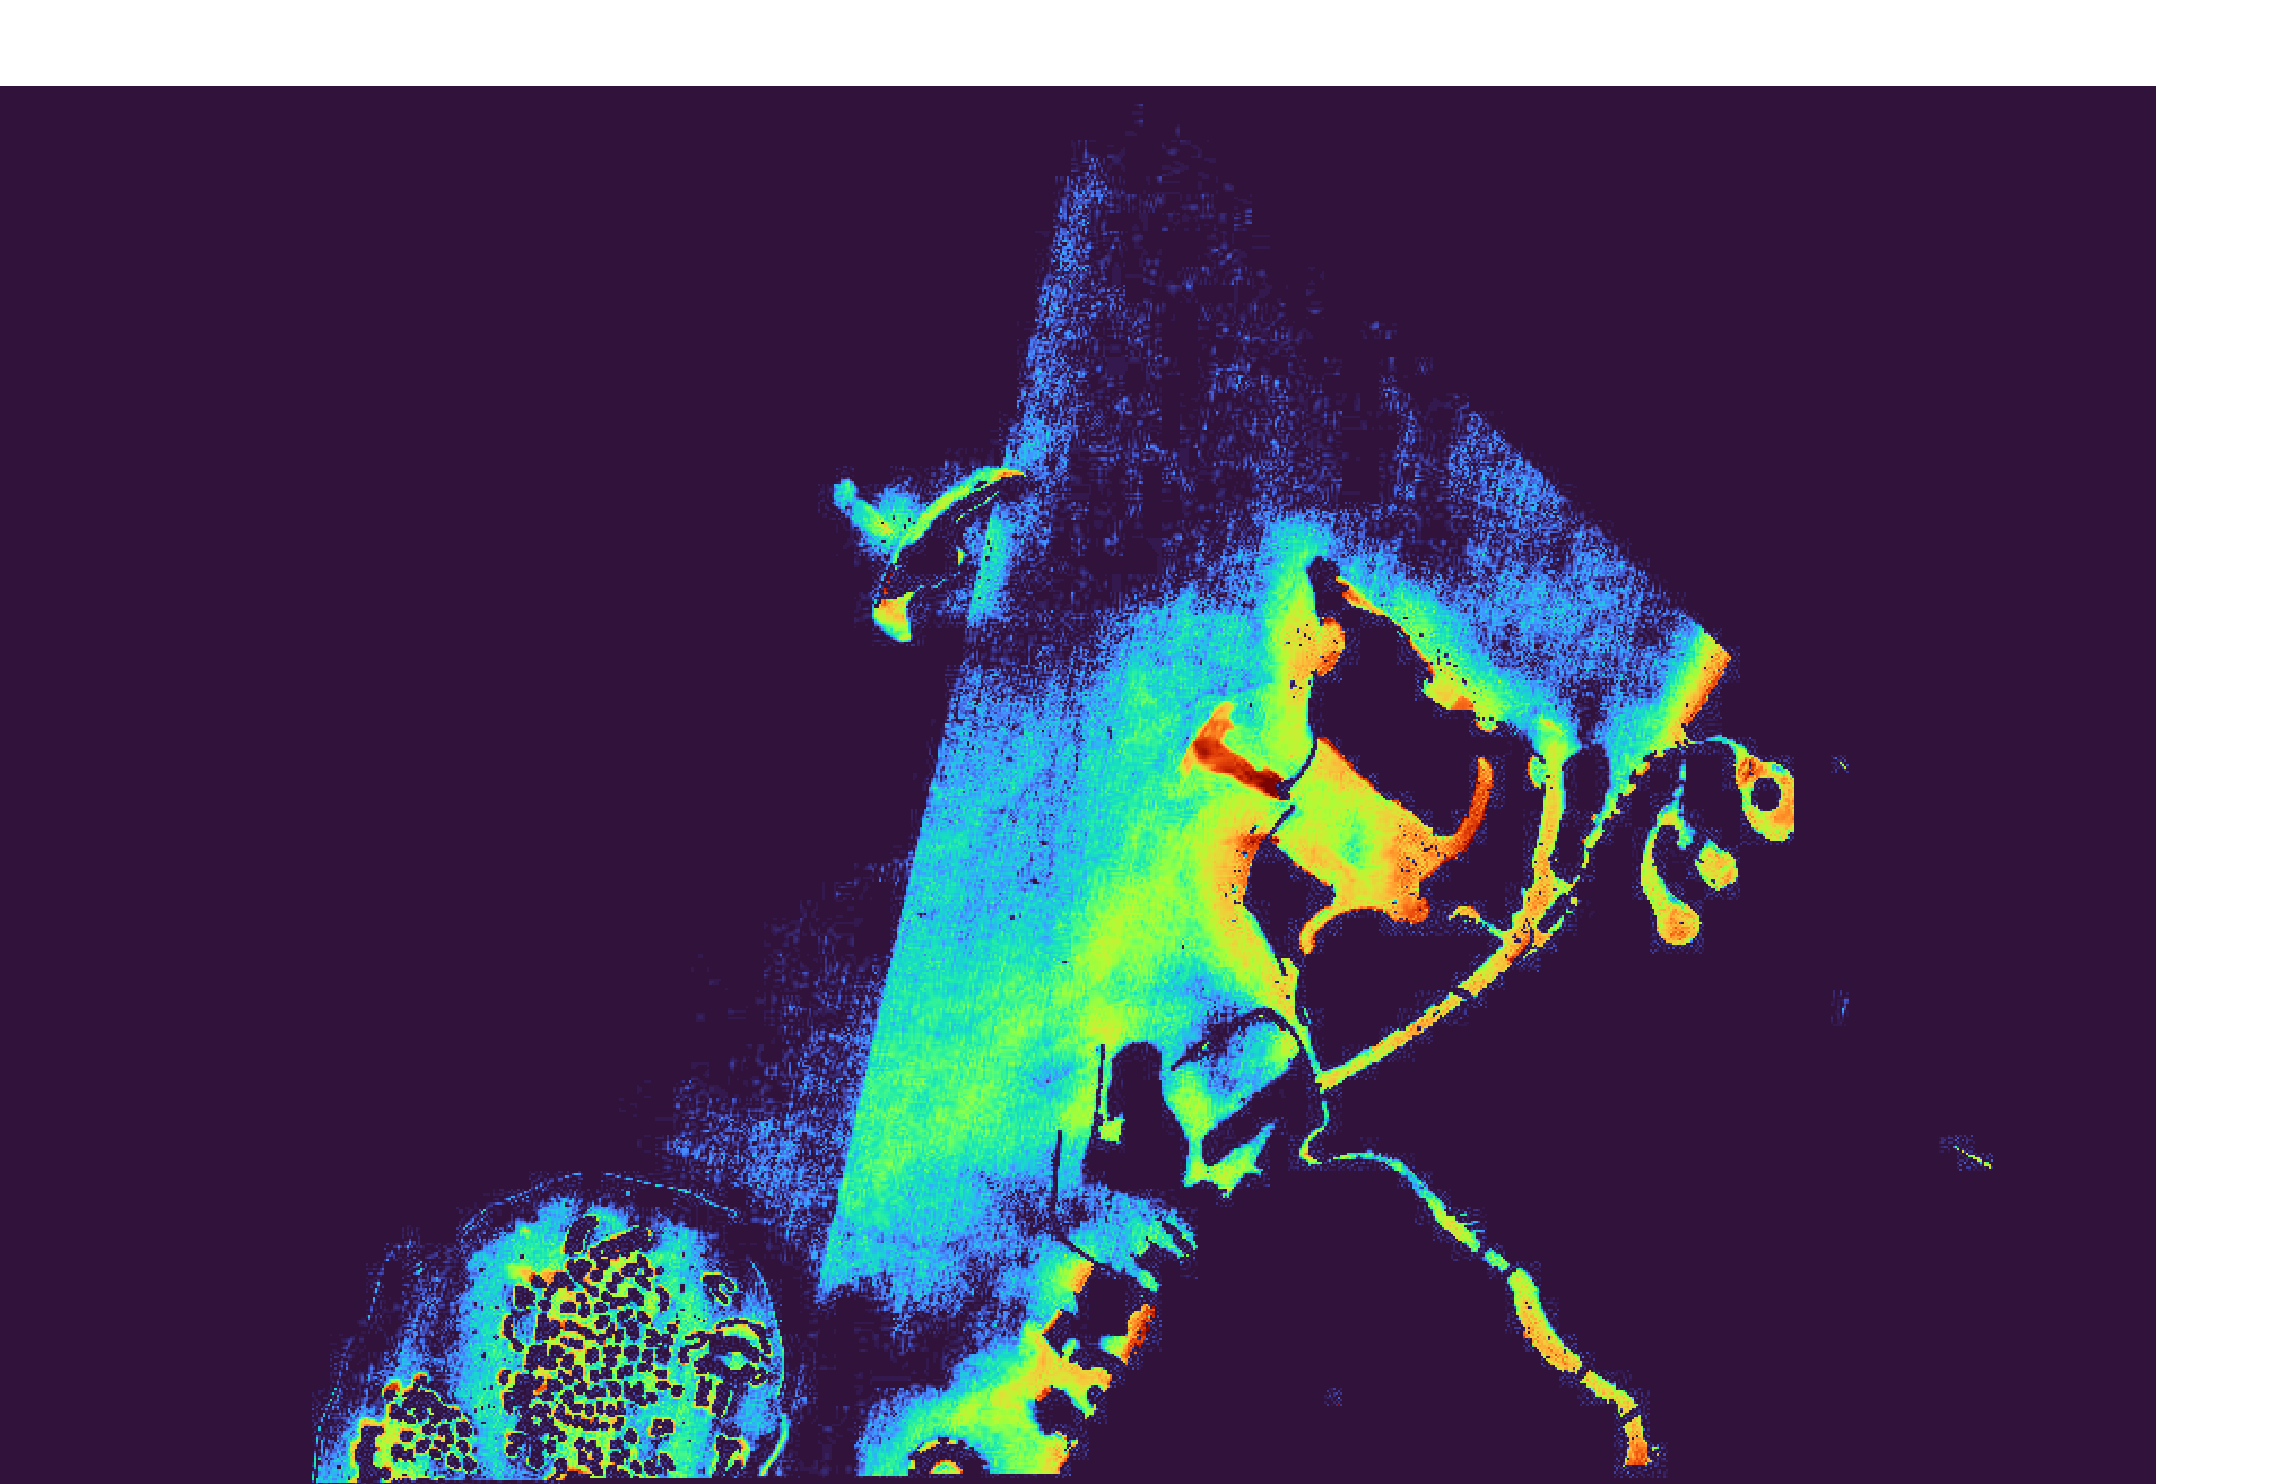
Real coastlines, real depth.
1,000 credits
on the house.
No vessel, no licence server, no quote. Scout and process your first coastlines today, then scale on a simple credit model.
Create free account →Bathymetry,
by API.
Scout, process and pull depth data programmatically. Bearer keys, credit-metered, rate-limited.
Read the API docs →POST /api/navbathy/scout
Authorization: Bearer nav_live_…
# Process to a depth GeoTIFF
POST /api/navbathy/process
→ { "job_id": "…", "status": "queued" }
GET /api/navbathy/jobs/:id
→ { "tiff_url": "…", "credits_remaining": 950 }
From the blog.
Field notes on satellite bathymetry, S-44 compliance and ocean intelligence.